Companies
Robotics company moves: funding rounds, product launches, partnerships, acquisitions and market entries.
Robotics company moves: funding rounds, product launches, partnerships, acquisitions and market entries.
Latest in Companies
382 storiesHigher-Order Morphology Priors for Quadruped Reinforcement Learning Under Actuator Degradation
arXiv:2610.10934v1 Announce Type: new Abstract: Actuator degradation turns quadruped locomotion into a coordination problem requiring joints to compensate for l…
Neural Networks for Temporal Pattern Recognition and Dynamic Arm Gesture Speed Estimation for Robot Control
arXiv:2610.11631v1 Announce Type: new Abstract: Deploying intelligent robotic systems that interact with humans through gestures requires neural networks capabl…
Higher-Order Action Supervision Makes A Strong Policy Class
arXiv:2610.11175v1 Announce Type: new Abstract: Modern data-driven decision-making methods, such as imitation learning (IL) and reinforcement learning (RL), hav…
ActiveReg: Information-Driven Active Regional Probing for Partial-to-Full Bone Registration
arXiv:2610.11003v1 Announce Type: new Abstract: Accurate bone registration is essential for orthopedic surgical navigation and robotic assistance. In a common w…
SDPAD: A Fully Spike-Driven Pipeline for End-to-End Autonomous Driving
arXiv:2610.11583v1 Announce Type: new Abstract: End-to-end autonomous driving demands trajectory planners that are both highly accurate and cheap enough for edg…
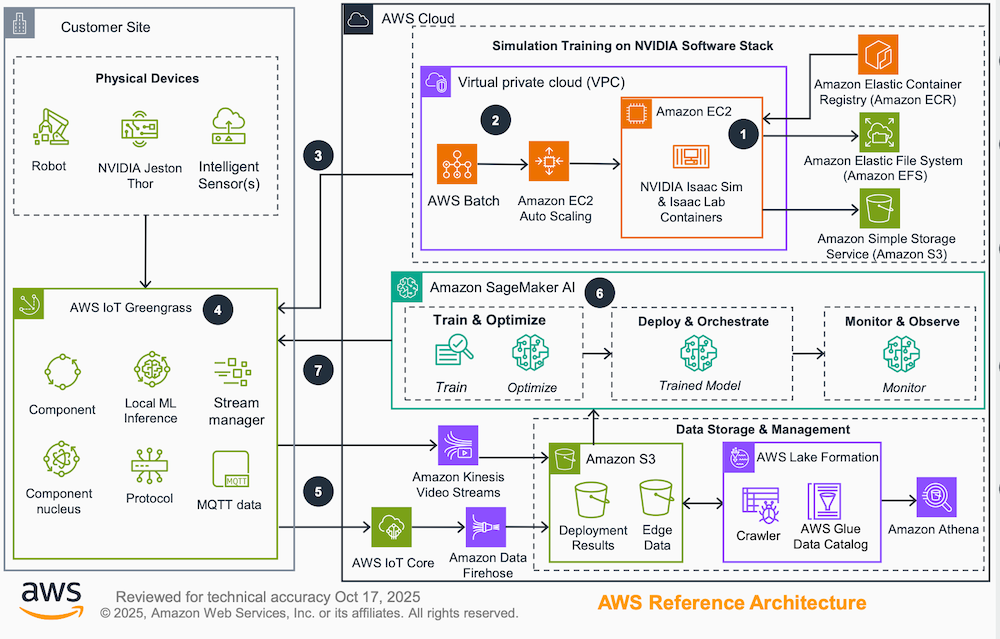
AWS launches open-source Physical AI Toolchain for robotics
The toolchain combines AWS and NVIDIA tools for synthetic data generation, model training, simulation and validation, edge deployment, and continuous improvemen…
YUBI-STAG: Contact and Semantic-Rich Alignment for VLAs via Automated Video-Language Grounding
arXiv:2610.09718v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models acquire broad manipulation capabilities via large-scale pretraining, yet eli…
Making Task Abstractions Executable: Control-Aware Layout Repair for a Fixed Controller
arXiv:2610.10281v1 Announce Type: new Abstract: A task abstraction can specify the intended events while its spatial layout prevents a fixed agent and controlle…
Anytime-Feasible First-Order Optimization via Safe Sequential QCQP
arXiv:2511.19675v2 Announce Type: replace-cross Abstract: This paper presents the Safe Sequential Quadratically Constrained Quadratic Programming (SS-QCQP) algo…
LeCuration: A Tiny World Model as a Data Curation Multi-Tool
arXiv:2610.09285v1 Announce Type: cross Abstract: Many applications of physical AI run within finite or closed physical worlds with a limited set of physical la…
PTC acquisition positions Schneider Electric to challenge Siemens
The Schneider Electric acquisition of PTC gives it a 'digital thread' from design through operations, but it needs to integrate data and software, says Interact…
Reactive Exploration of Unknown Environments for Redundant Robots using Virtual Model Control
arXiv:2610.08110v1 Announce Type: new Abstract: The exploration of confined, occluded, and partially known spaces poses significant challenges in robotic manipu…
ROMA: LLM System for Real-World Object-Centric Multi-Sensory Active Perception
arXiv:2610.06955v1 Announce Type: new Abstract: Humans inherently understand the physical world through an active process. When sensory evidence is insufficient…
ProactiveVLA: Augmenting Embodied Memory through Proactive Environment Exploration
arXiv:2610.06999v1 Announce Type: new Abstract: Rapid adaptation to a new environment requires a robot to acquire useful knowledge about local objects, states, …
Pareto-Optimal Entropy-Regularized Trajectory Optimization
arXiv:2610.08532v1 Announce Type: new Abstract: Trajectory optimization (TO) under nonlinear dynamics, actuation limits and collision avoidance constraints is a…
LBA-CBF: Rapidly Adaptive Safety Filters via Parallel Dynamics Inference
arXiv:2610.08765v1 Announce Type: new Abstract: Control barrier functions (CBFs) certify commands through an assumed dynamics model, so an abrupt, unmeasured re…
UWB Meets Crazyflow: Simulating Degraded Feedback at Scale for Aerial Robotics
arXiv:2610.08225v1 Announce Type: new Abstract: In this work, we introduce Crazyflow, an accurate, differentiable simulator built on JAX. By leveraging jit comp…
The Robot Is Not Its Description: GaugeBench for Representation Robustness in Morphology-Aware Policies
arXiv:2610.07597v1 Announce Type: new Abstract: A robot description does more than specify a physical mechanism: it also encodes arbitrary conventions, such as …
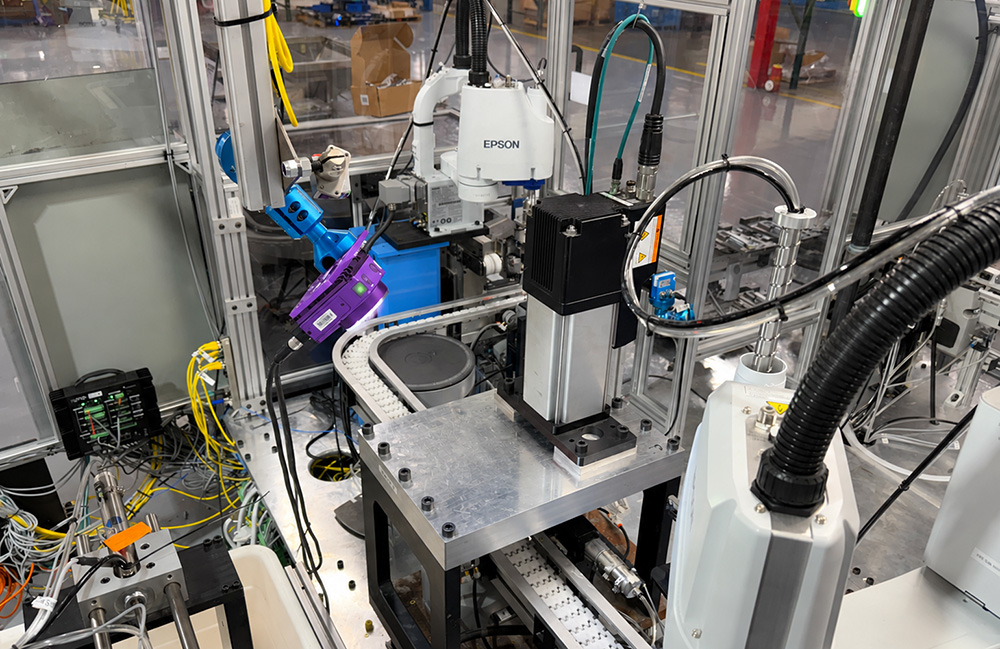
Overview AI launches OV Spark line of AI inspection cameras
The OV Spark and OV Spark Pro AI inspection cameras are available now through Overview AI and its distribution partners. The post Overview AI launches OV Spark …
How to Find and Reuse Policies for Continuous Adaptation in Lifelong Reinforcement Learning
arXiv:2610.03119v1 Announce Type: cross Abstract: In lifelong reinforcement learning, retaining previously learned policies is not sufficient for effective tran…
Permutation Robustness Is Not Enough: Action Collapse in Multi-Agent Transformer Policies
arXiv:2610.02848v1 Announce Type: new Abstract: Transformer policies are attractive for multi-agent robot learning because self-attention can model interactions…
Rewind-IL: Online Failure Detection and State Respawning for Imitation Learning
arXiv:2604.16683v2 Announce Type: replace Abstract: Imitation learning has enabled robots to acquire complex visuomotor manipulation skills from demonstrations,…
ActiveWAM: Evidence-Aware Active Vision for World-Action Models
arXiv:2610.01698v1 Announce Type: new Abstract: Active vision manipulation requires a policy to control both its camera and its end-effectors, yet camera motion…
Probabilistic Plan Legibility with Off-the-shelf Planners
arXiv:2610.00065v1 Announce Type: new Abstract: Legible planning is the creation of plans that best disambiguate their goals from a set of other candidates from…
Whole-Body Aerial Grasping and Lifting via Partial Visual Observations
arXiv:2610.00404v1 Announce Type: new Abstract: Aerial grasp-and-lift tasks require whole-body coordination across approach, acquisition, and lifting under part…
Bounded-Fidelity Sim-as-Demo-Stage: Mocap Handoff for Governance Benchmarks
arXiv:2610.00008v1 Announce Type: new Abstract: Sim-to-real research pursues physics fidelity as a primary objective: simulators are judged by how closely they …
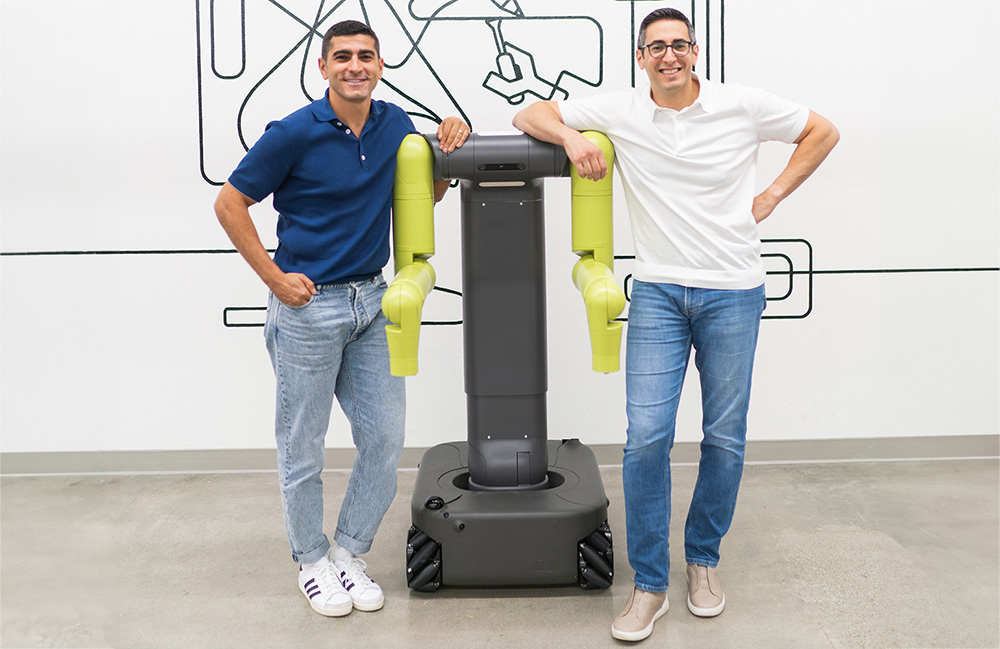
How Maven Robotics plans to automate industrial work, one task at a time
With the $100 million it raised earlier this month, Maven Robotics is looking towards mass producing its mobile manipulator robot. The post How Maven Robotics p…
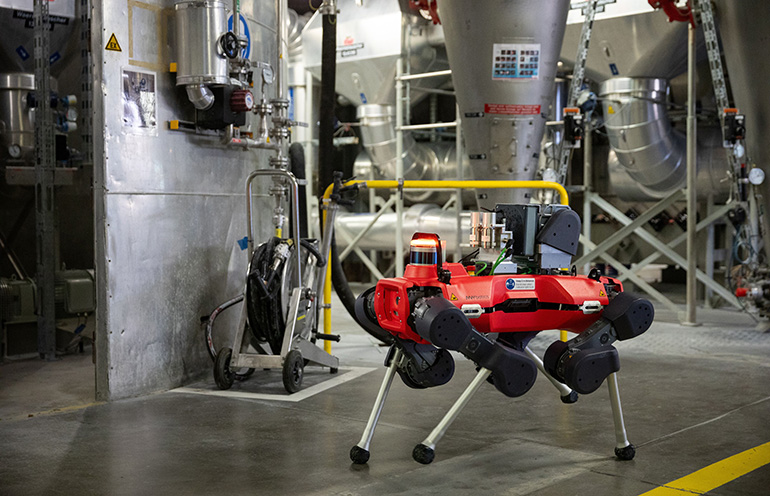
ANYbotics launches Shift to streamline robot fleet operations, scale inspections
ANYbotics designed Shift to help maintenance teams run industrial inspections, detect failing equipment, and turn data into work orders. The post ANYbotics laun…
mmHRI: Towards Privacy-Preserving Human-Robot Interaction with Millimeter-Wave Radar
arXiv:2609.34220v2 Announce Type: replace Abstract: Assistive robots increasingly operate in many human-centered environments and perform various human-robot in…
SynIL: Leveraging Synergy for Offline Imitation Learning from Imperfect Demonstration Datasets
arXiv:2609.38225v1 Announce Type: new Abstract: Imitation learning enables robots to acquire complex skills directly from massive demonstration datasets, but it…